01research agenda
Predict
Predictive world models for embodied agents
Build compact latent states grounded in vision, proprioception, and contact, with the long-term goal of self-correcting dexterous manipulation.
Undergraduate researcher / Renmin University of ChinaBeijing, China
B.S. candidate in Artificial IntelligenceGaoling School of Artificial Intelligence, Renmin University of China
Verifiable world models for embodied agents
How can an agent recognize when its evidence is no longer sufficient for action, then correct the right part of its state instead of continuing blindly?
Research position
03 connected questions
How can an agent recognize when its evidence is no longer sufficient for action, then correct the right part of its state instead of continuing blindly?
Reliable embodied agents need predictive states whose claims remain traceable to vision, proprioception, contact, and the origin of information.
I study how agents can ground decisions in the right evidence, detect when that evidence is insufficient, and make targeted corrections before acting.
Self-correcting dexterous manipulation through latent predictive world models.
Predict
Build compact latent states grounded in vision, proprioception, and contact, with the long-term goal of self-correcting dexterous manipulation.
Verify
Trace which evidence may control an action, and detect when environmental change breaks an operational obligation rather than merely changing an incidental value.
Correct
Locate spatiotemporal evidence at the decoding layers where video grounding can still be repaired, then test inconsistent temporal reasoning.
Decision boundary / research agenda
Vision, proprioception, contact, and provenance converge at an evidence boundary. The question is whether to act, correct the relevant state, or stop when evidence is insufficient.
Personal archive / 02 frames
Two photographs, presented without a brief.
Selected work
02 focused records
Embodied Dexterity
Real-system work spanning dexterous-hand policy training, cross-platform integration, and ongoing work toward joint G1 whole-body and dexterous-hand training.
Trained a Wuji dexterous hand mounted on a Tianji robotic arm across multiple manipulation tasks using NVIDIA GR00T. Migrated and integrated the same Wuji hand onto a Unitree G1 humanoid and coupled it with the team's GMT control stack.
Industrial research / Apr. 2026-present
Two completed foundations, one active training track, and one planned data track converge on the current G1 whole-body and dexterous-hand program.
STEAR
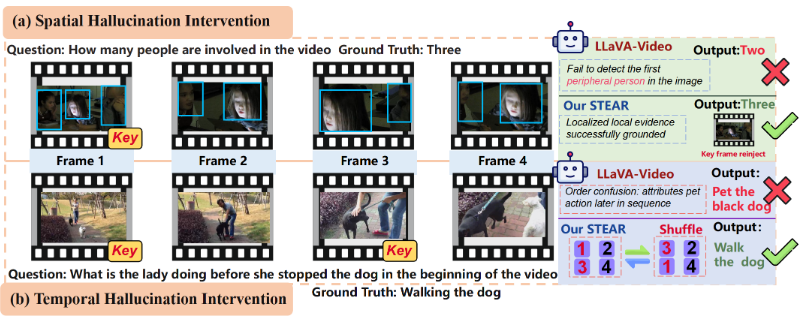
STEAR: Layer-Aware Spatiotemporal Evidence Intervention for Hallucination Mitigation in Video Large Language Models
At high-entropy decoding steps, one token-conditioned middle-layer evidence hypothesis can support grounding repair and a temporal counterfactual check.
STEAR selects token-conditioned visual evidence, reinjects it at grounding-sensitive middle layers, and reuses it to construct temporal counterfactuals within a single video-encoding pass.
Publications
03 public preprints
PACT
Untrusted information becomes dangerous when its provenance is allowed to bind an authority-bearing tool argument.
PACT assigns semantic roles to tool arguments, tracks value provenance across replanning, and checks each argument against a role-specific trust contract before execution.
SkillGuard
A skill drifts when environmental change violates a role-bearing execution contract, not whenever a referenced value changes.
SkillGuard separates operational obligations from incidental mentions, validates role-bearing environment contracts, and uses violations to localize repair.
STEAR
At high-entropy decoding steps, one token-conditioned middle-layer evidence hypothesis can support grounding repair and a temporal counterfactual check.
STEAR selects token-conditioned visual evidence, reinjects it at grounding-sensitive middle layers, and reuses it to construct temporal counterfactuals within a single video-encoding pass.
Research trajectory / 2026
The long-term agenda is embodied: compact predictive states, grounded in the evidence that matters, able to detect and repair their own failures before action.
Record
Education / experience / recognition
Gaoling School of Artificial Intelligence
Experience
Apr. 2026-Present / ongoing
Project Lead · Beijing Noetix Robotics Technology Group Co., Ltd.
Real-system work spanning dexterous-hand policy training, cross-platform integration, and ongoing work toward joint G1 whole-body and dexterous-hand training.
Trained a Wuji dexterous hand mounted on a Tianji robotic arm across multiple manipulation tasks using NVIDIA GR00T.
Migrated and integrated the same Wuji hand onto a Unitree G1 humanoid and coupled it with the team's GMT control stack.
Extending the system toward joint G1 whole-body and dexterous-hand training, with iterative work on coordination, manipulation, and robustness.
Planning a HumanEgo-inspired wearable-glasses demonstration and human-to-dexterous-hand retargeting pipeline to reduce task-specific real-robot demonstration collection.
Jun.-Aug. 2025 / completed
Deputy Captain · RUC-HUHA Humanoid Robot Team
Contributed to integration, real-robot debugging, and coordination for an 11-person humanoid robotics team.
Built and debugged the VR-to-ROS teleoperation pipeline, including relative coordinate mapping and proportional workspace scaling for dual-arm control.
Contributed to MoveIt2-based bimanual motion planning and sim-to-real deployment, including execution deviation, workspace, collision-avoidance, and safety debugging.
Selected recognition
2nd Place (Team)
RUC-HUHA Humanoid Robot Team
First Prize, Beijing Division
Beijing Outstanding Project Grant